Autonomous Systems
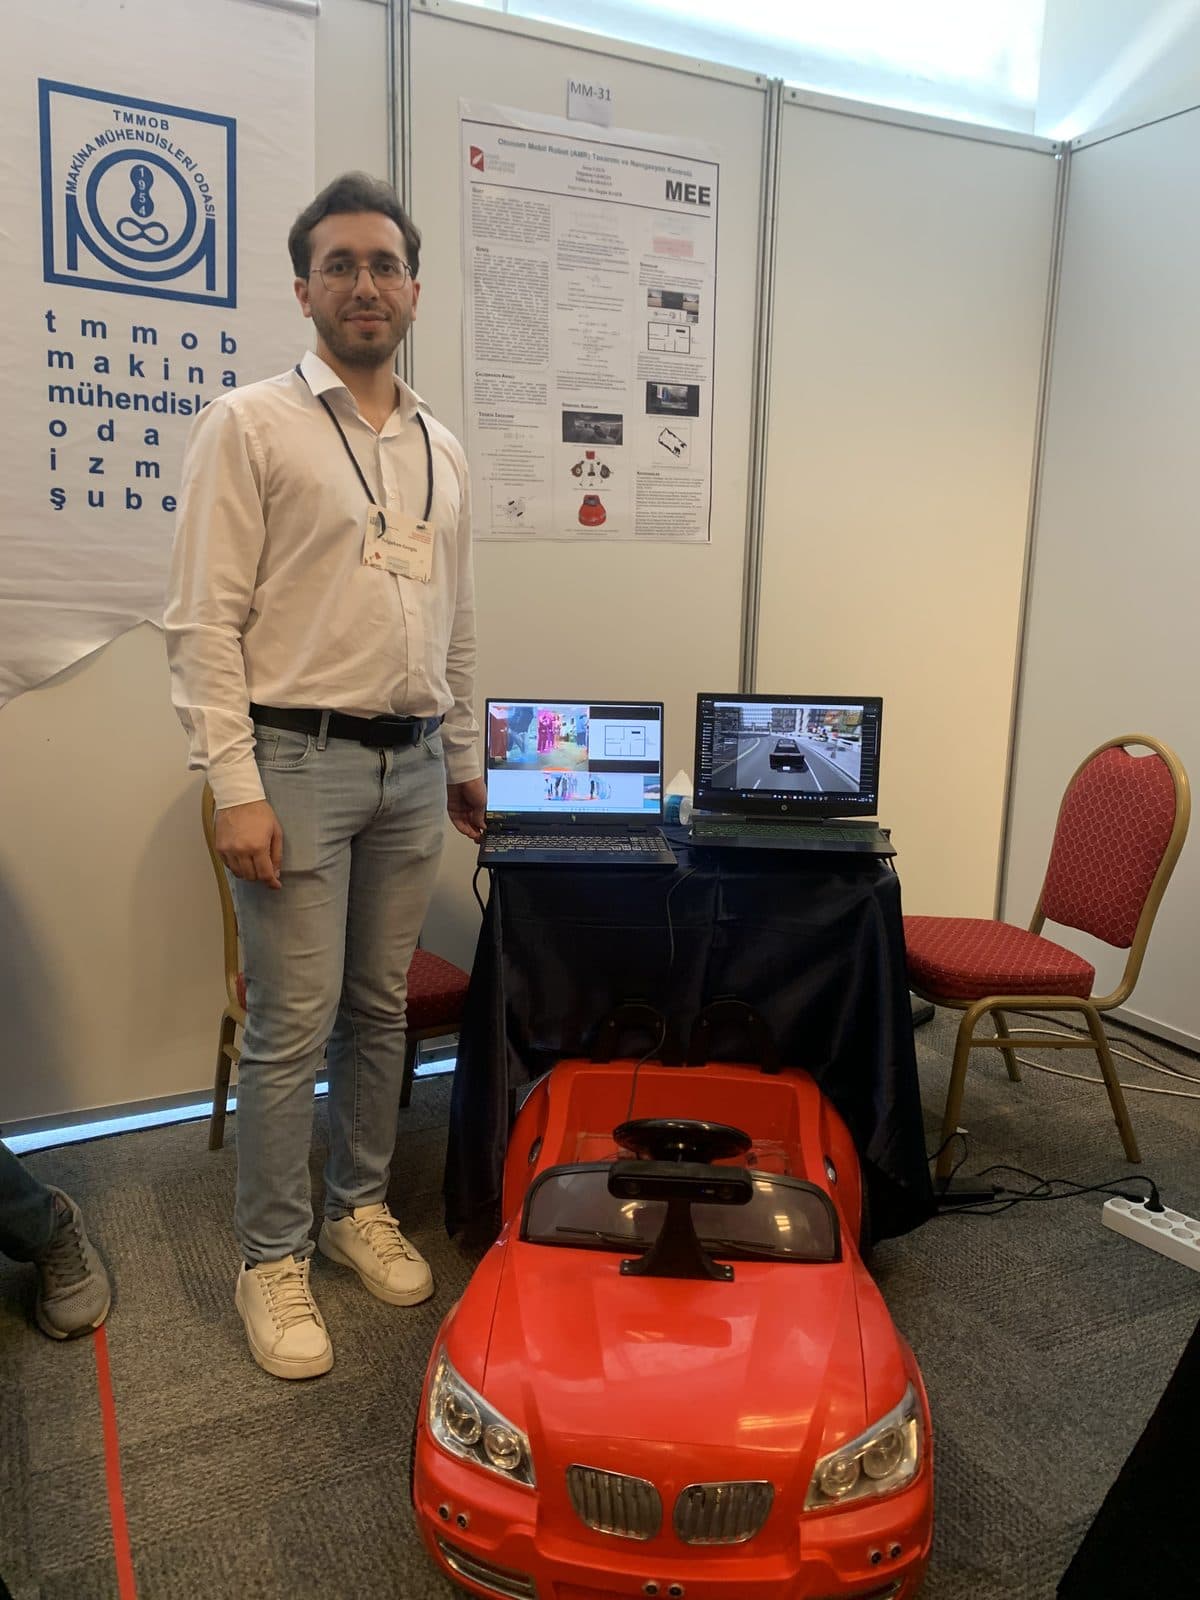
Design and Navigation Control of an Autonomous Mobile Robot (AMR)
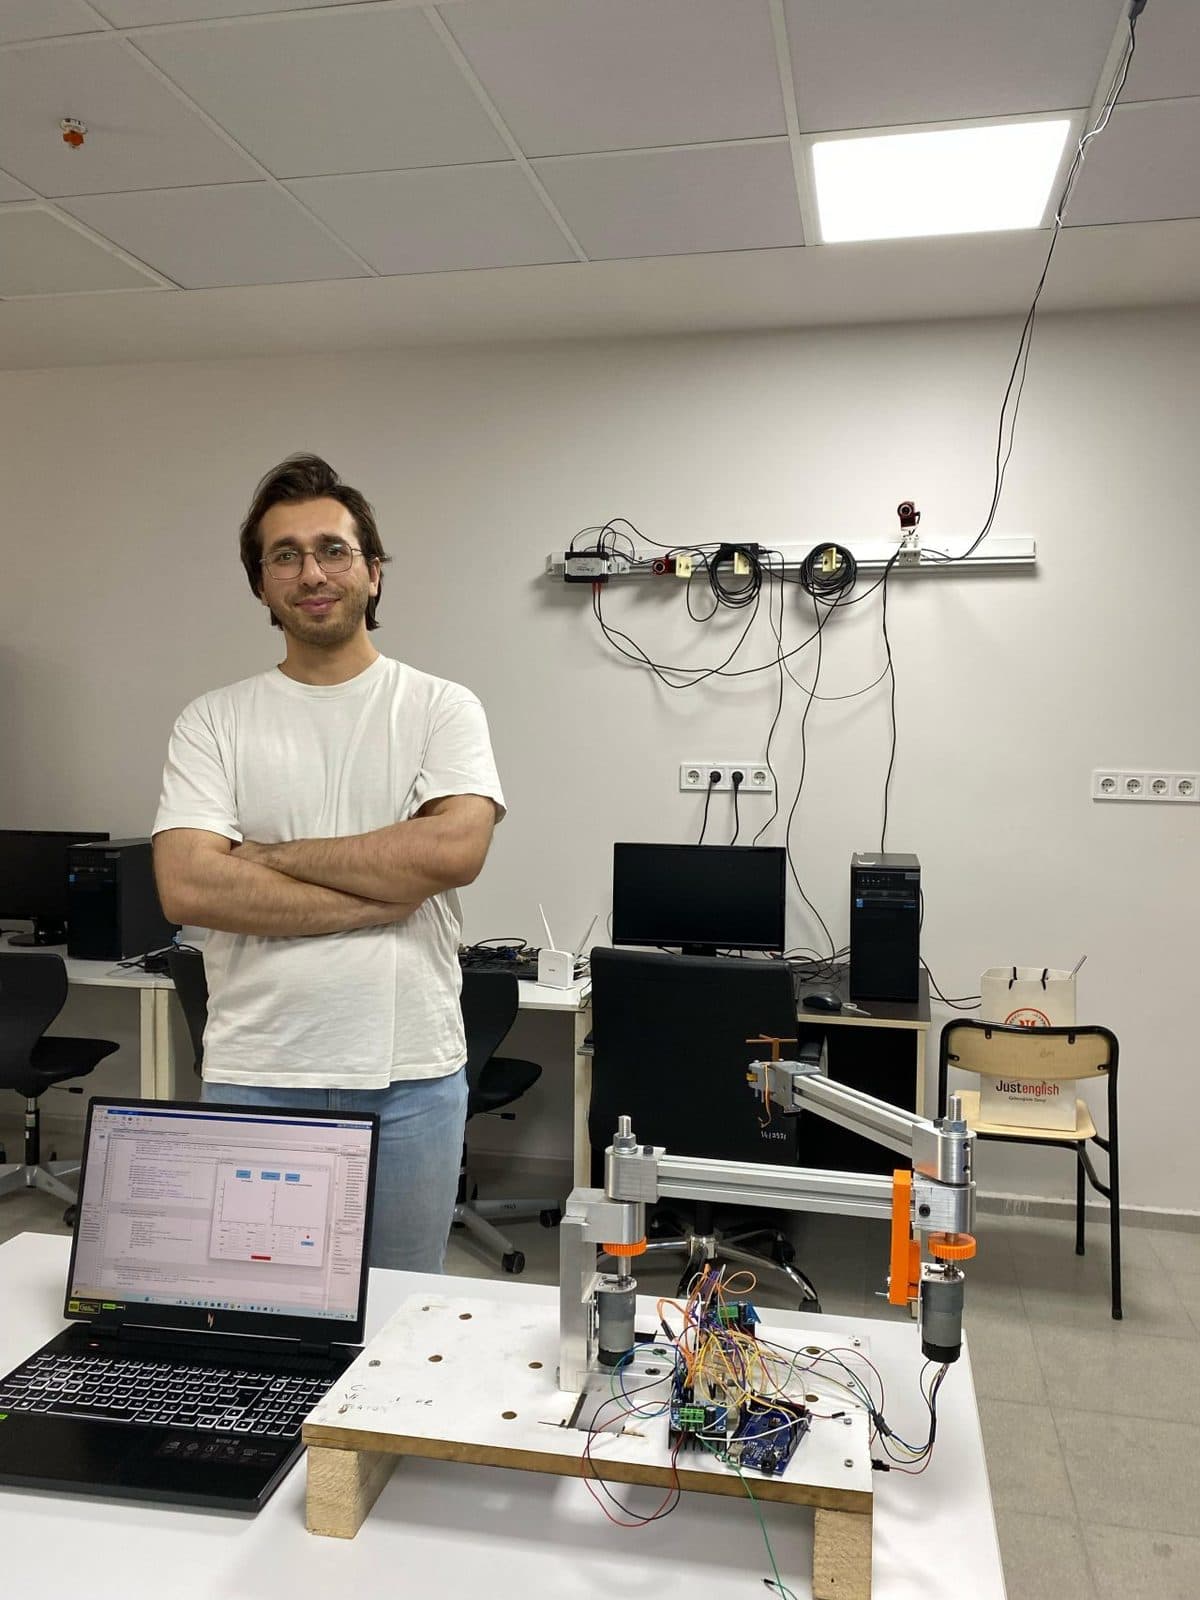
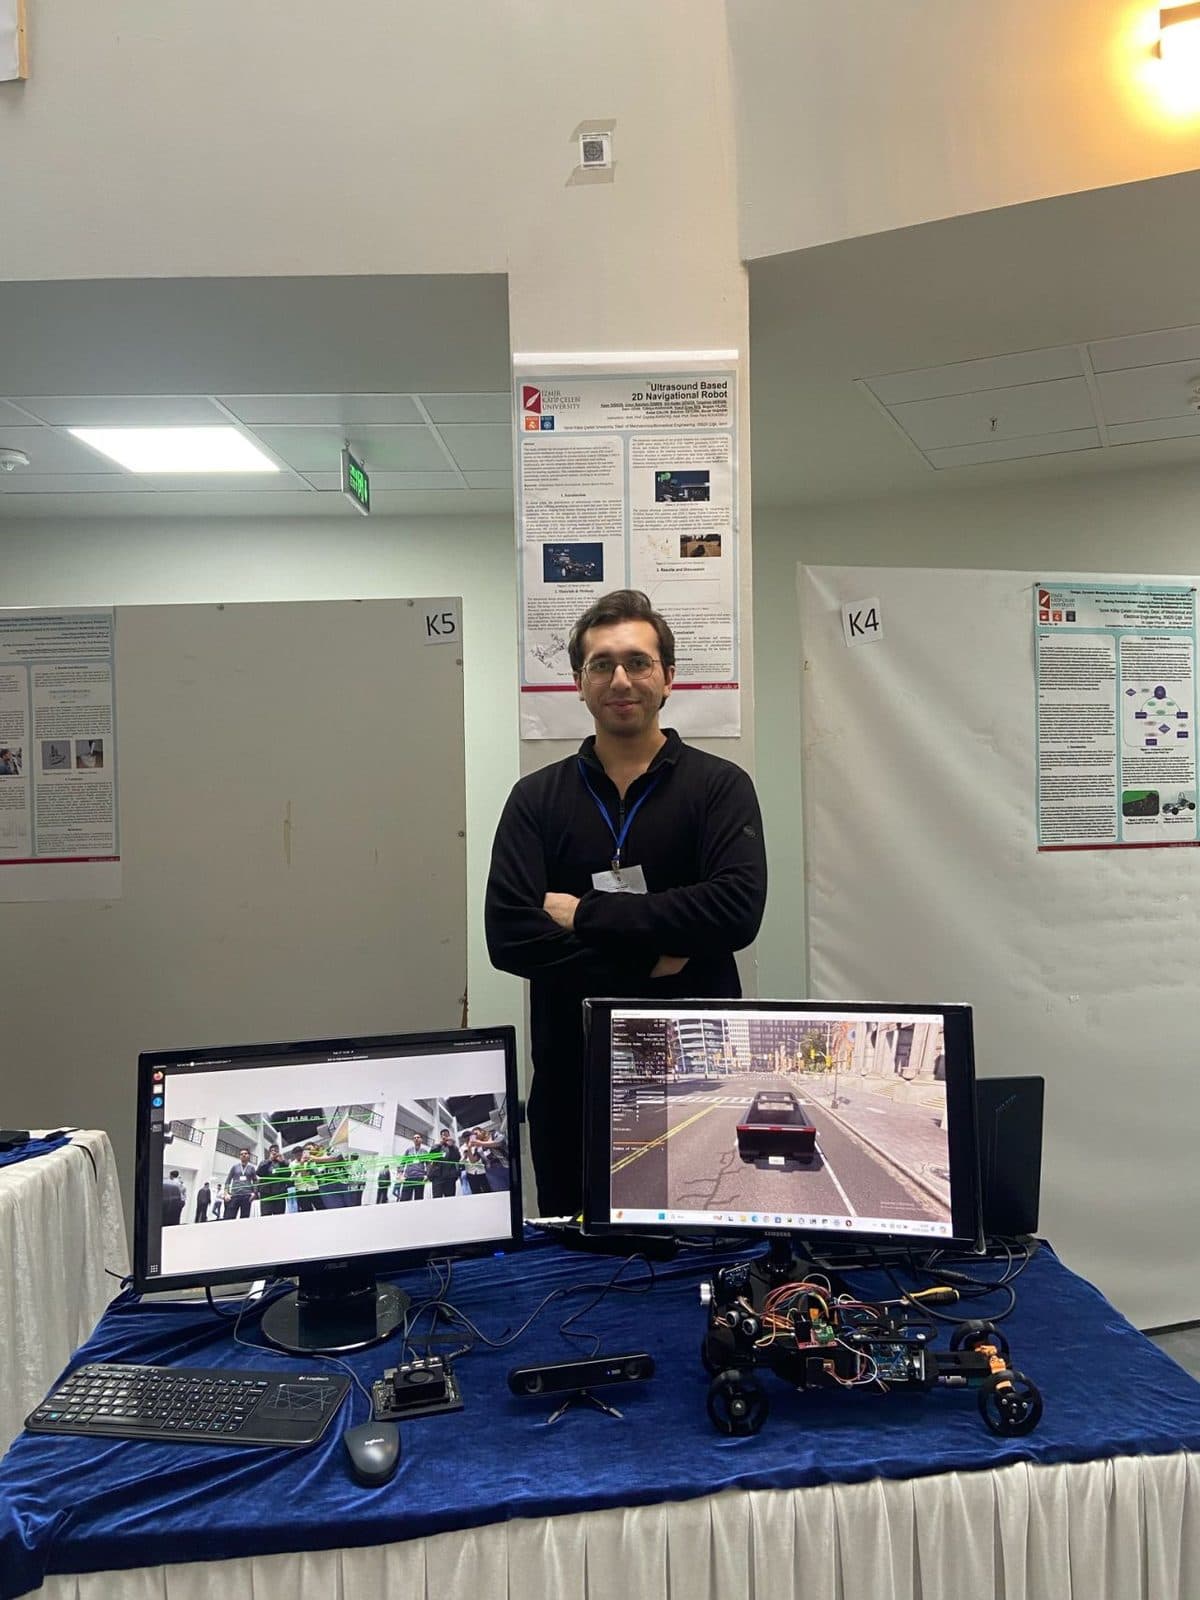
Graduation project: a fully autonomous mobile robot with a ZED2 stereo camera, YOLO-based object detection, Particle Filter localization and A* path planning. I led both software and hardware end to end.
- Python
- ZED2
- YOLO
- PID
- A*